M-206 Mechatronics
Automated Car and Elevator System
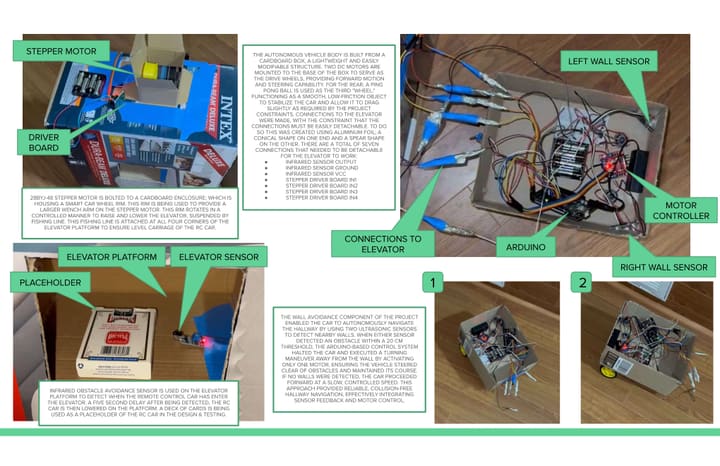
A mechatronics project involving the design and construction of an automated elevator and wall-avoidance vehicle system.
System Sequence
Designed a coordinated sequence in which an IR sensor detected the RC car, a stepper-motor elevator lowered it from 10 inches to 1 inch above the ground, and its exit triggered the next stage.
Vehicle Design
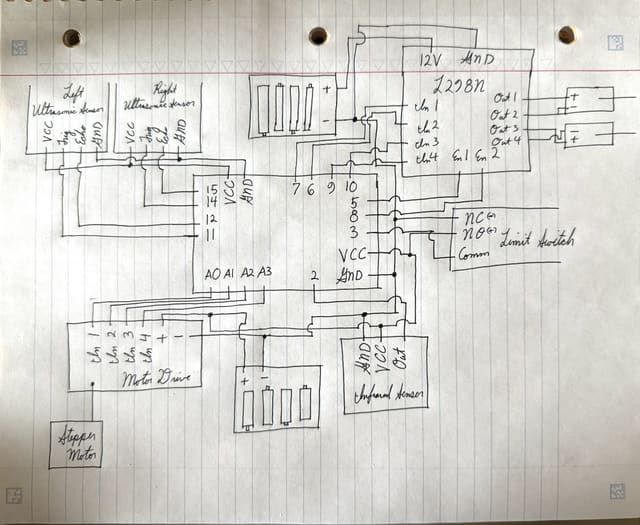
Built the autonomous vehicle from a lightweight cardboard chassis with two front DC drive motors, a ping-pong-ball rear support, an Arduino controller, an L298N motor driver, battery holders, and sensors.
Autonomous Control
Used a rear limit switch to start autonomous driving and two ultrasonic sensors to measure wall distance. The control logic moved the vehicle forward and made corrective turns when an obstacle was within 20 cm.
Result
Produced a functional integrated system that met the project constraints for automated elevator movement, vehicle release, and wall-avoiding hallway navigation.
Automated Car and Elevator System
Photos & figures
1 / 2
-
Completed automated elevator and wall-avoiding vehicle system.
-
Automated car and elevator system during testing.